AirLab projects

Research

Our work connects aerial sensing with computer vision and autonomous action in residential and road environments.

01
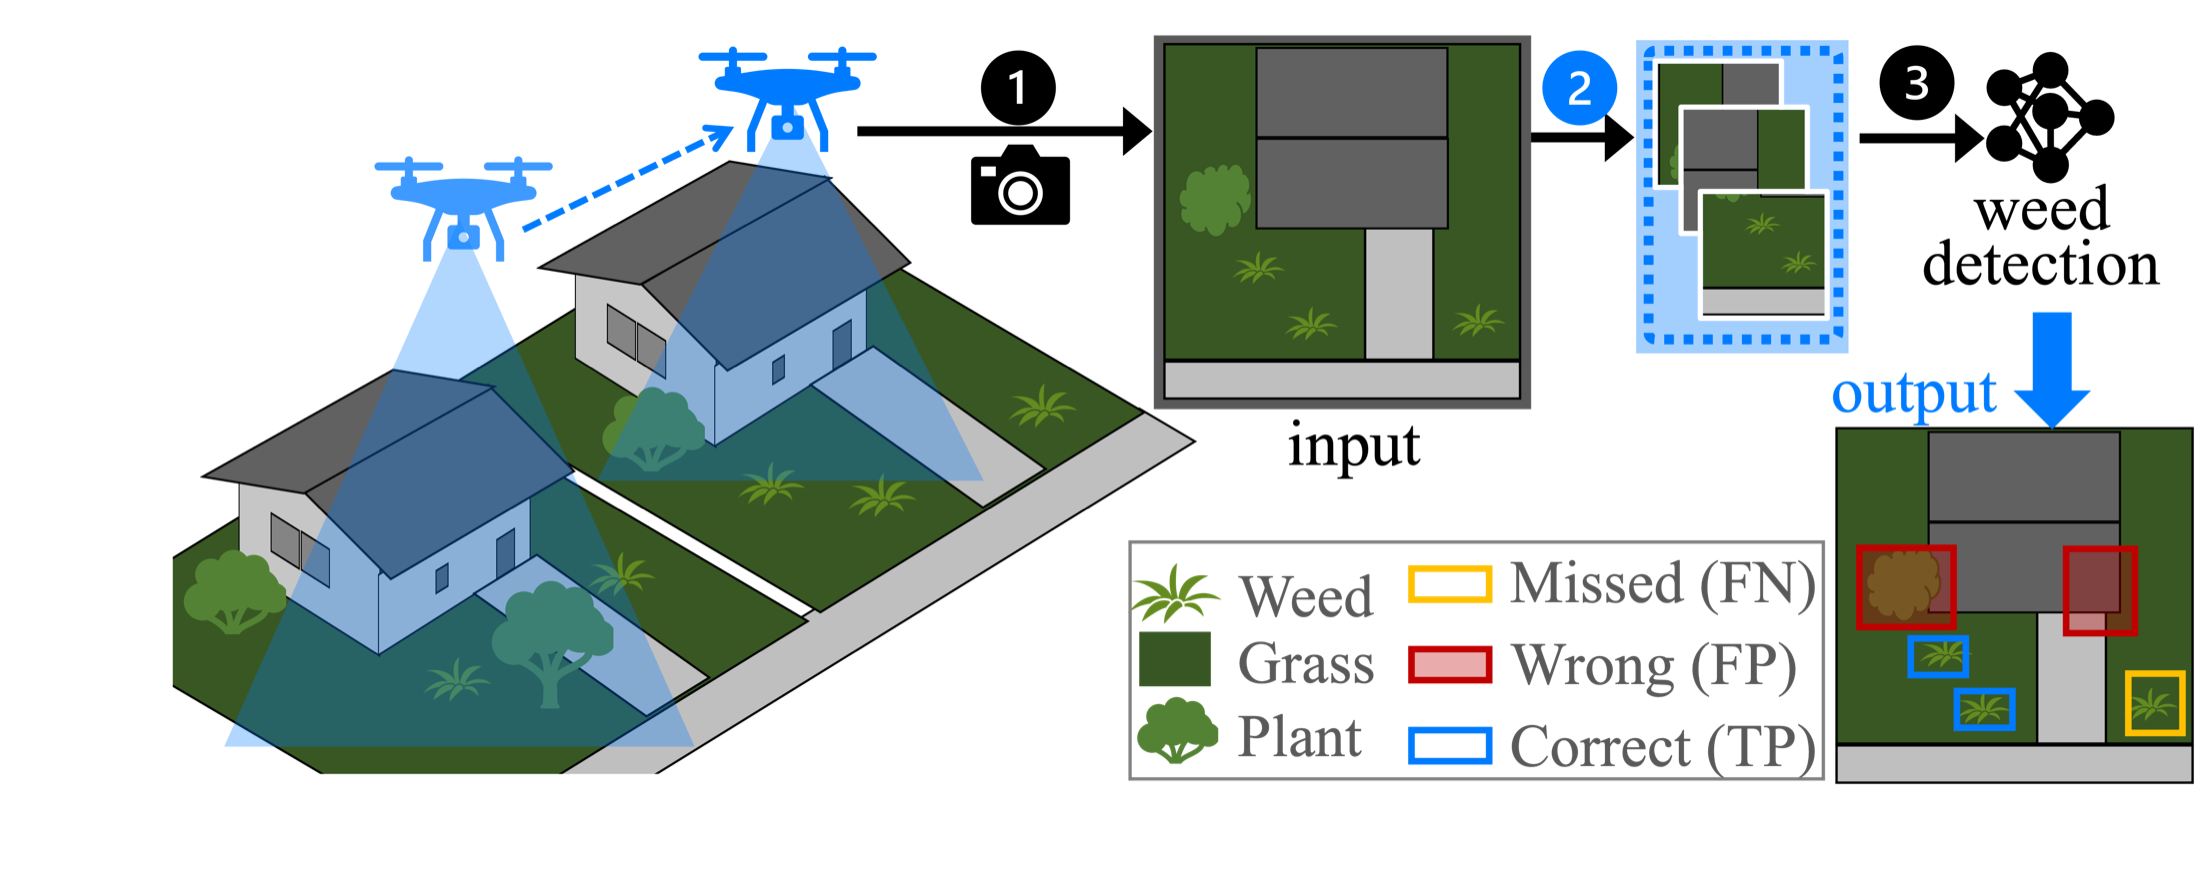
Diagram of drones collecting residential lawn images for aerial weed detection

Aerial perception · Residential environments

Aerial Weed Detection

A4AWD studies aerial weed detection in residential lawns, where weeds can be small, sparse, irregular, and difficult to distinguish from surrounding turfgrass.

Open project
02
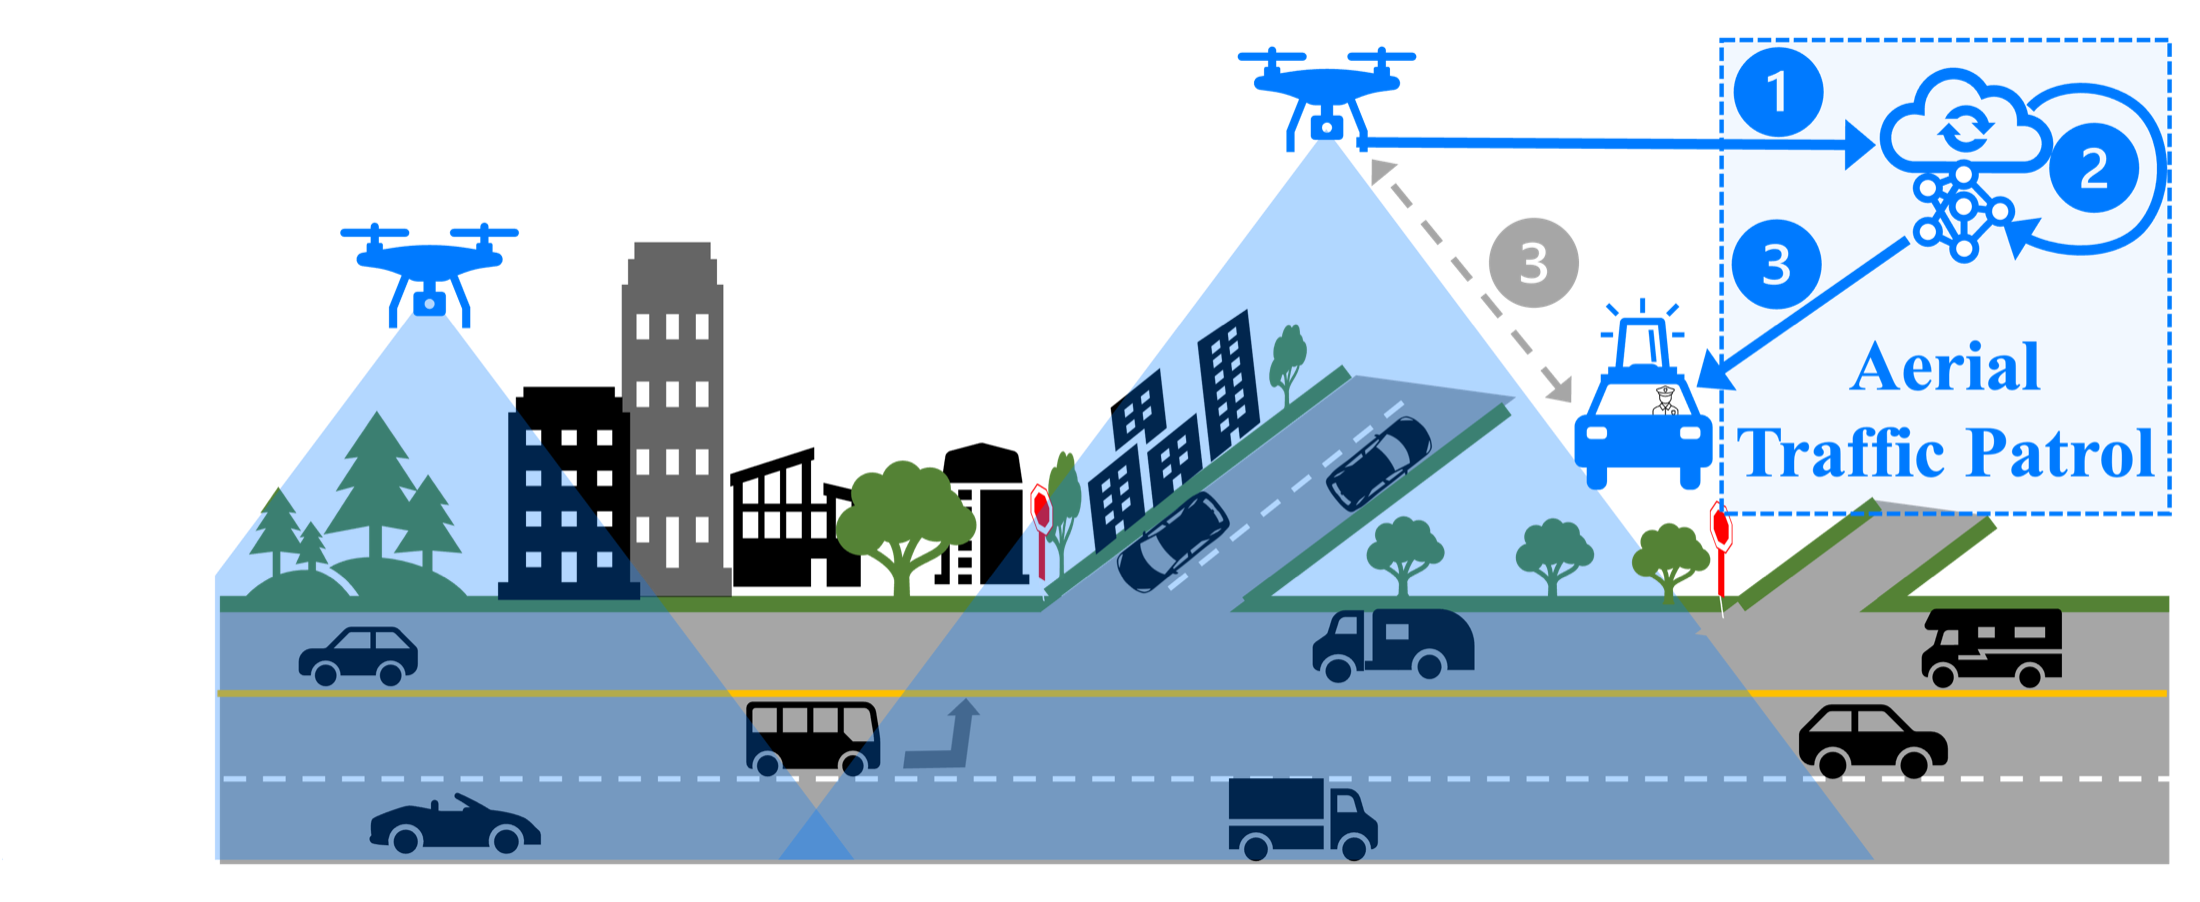
Diagram of drones observing vehicles and estimating traffic movement from the sky

On-drone analytics · Urban mobility

Aerial Traffic Patrol

Aerial Traffic Patrol explores how drones can observe road traffic and turn aerial video into useful vehicle detections, trajectories, and speed estimates.

Open project
03
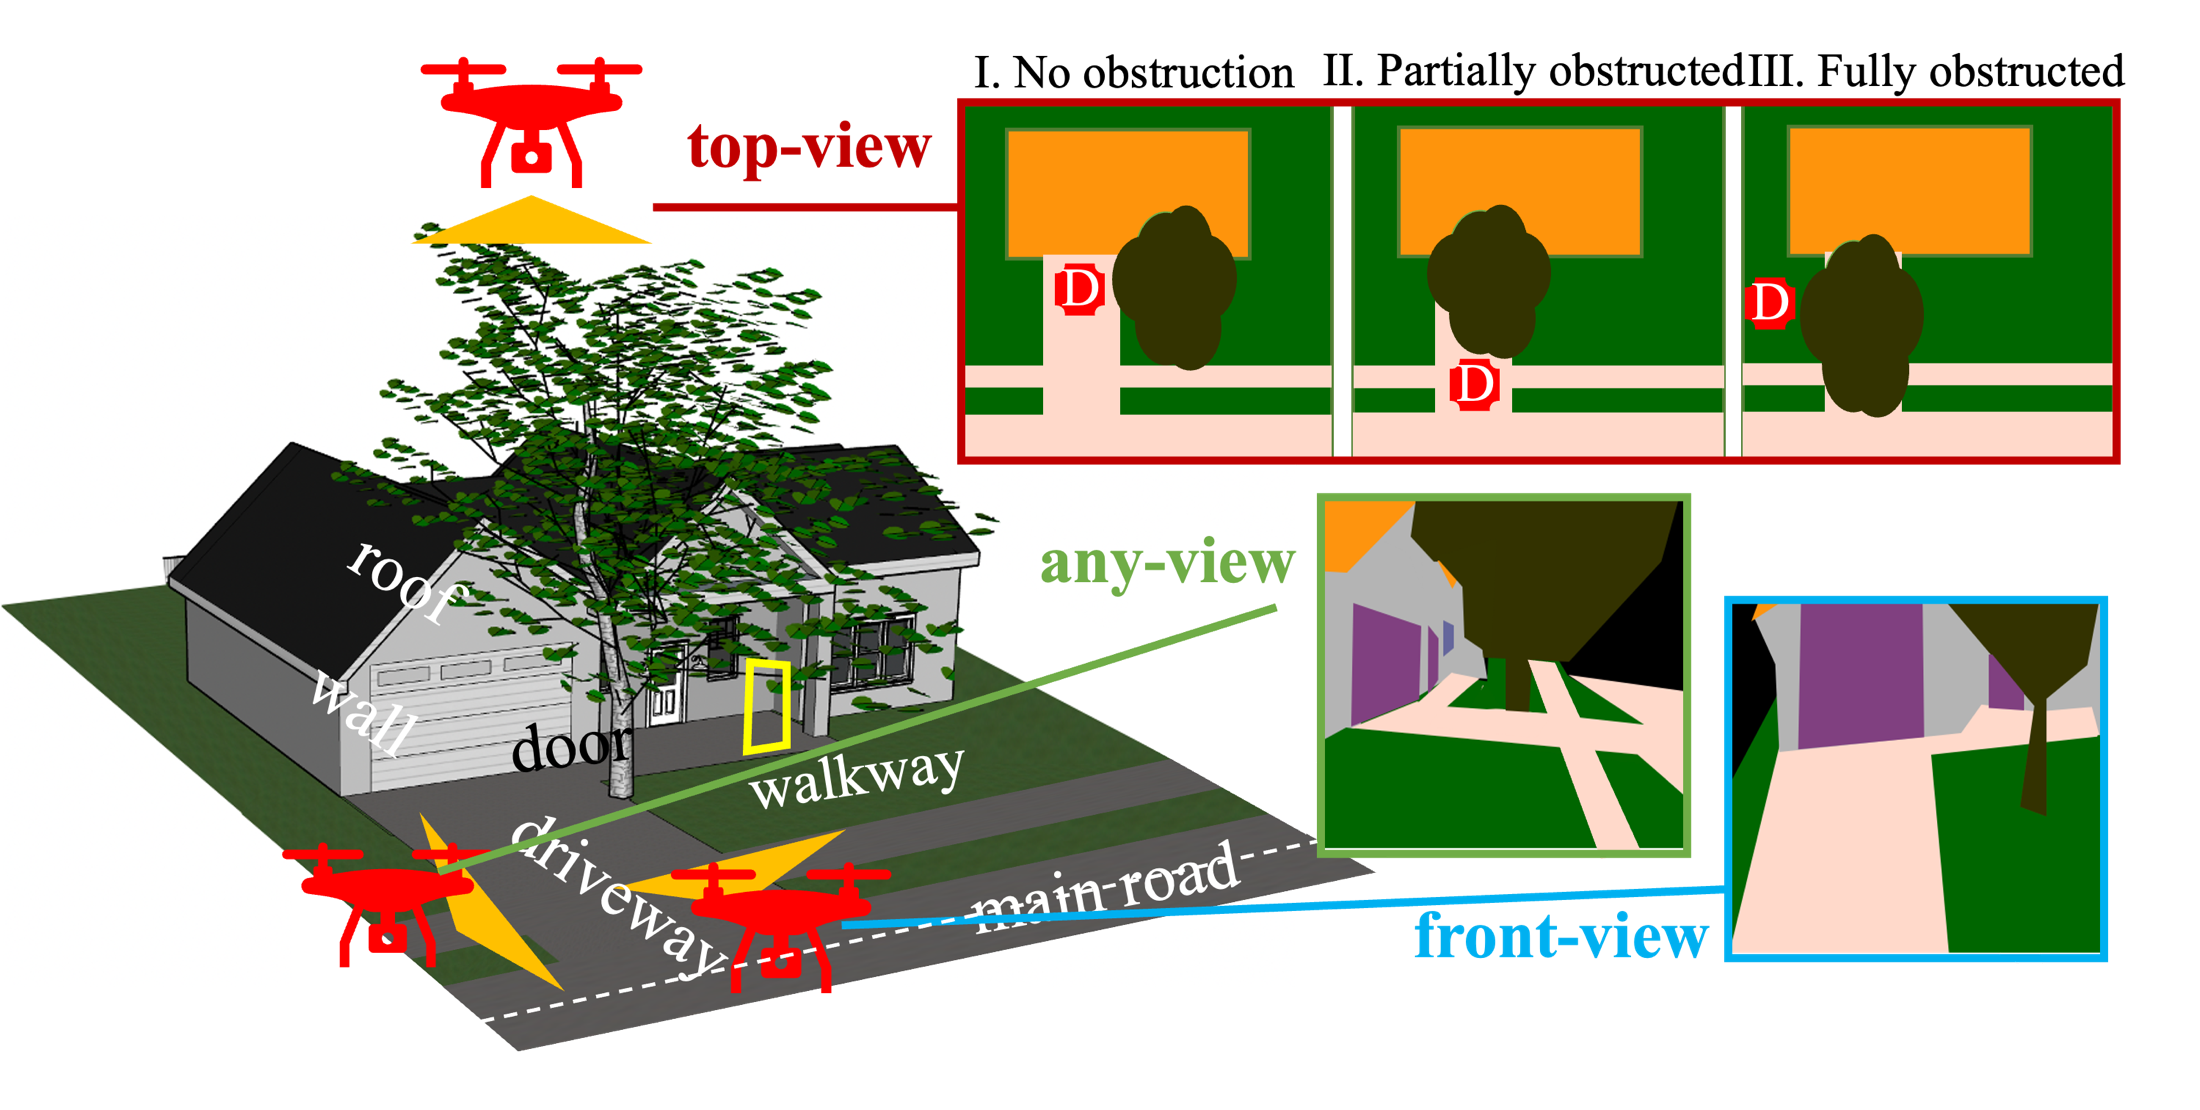
Diagram of a drone using house structure to approach a delivery point near a door

Robotic autonomy · Last-hundred-feet delivery

Autonomous Drone Delivery to Door

This project addresses the last-hundred-feet problem in autonomous drone delivery: moving from a broad destination to a practical drop-off point near a home's front or garage door.

Open project